Team Vector
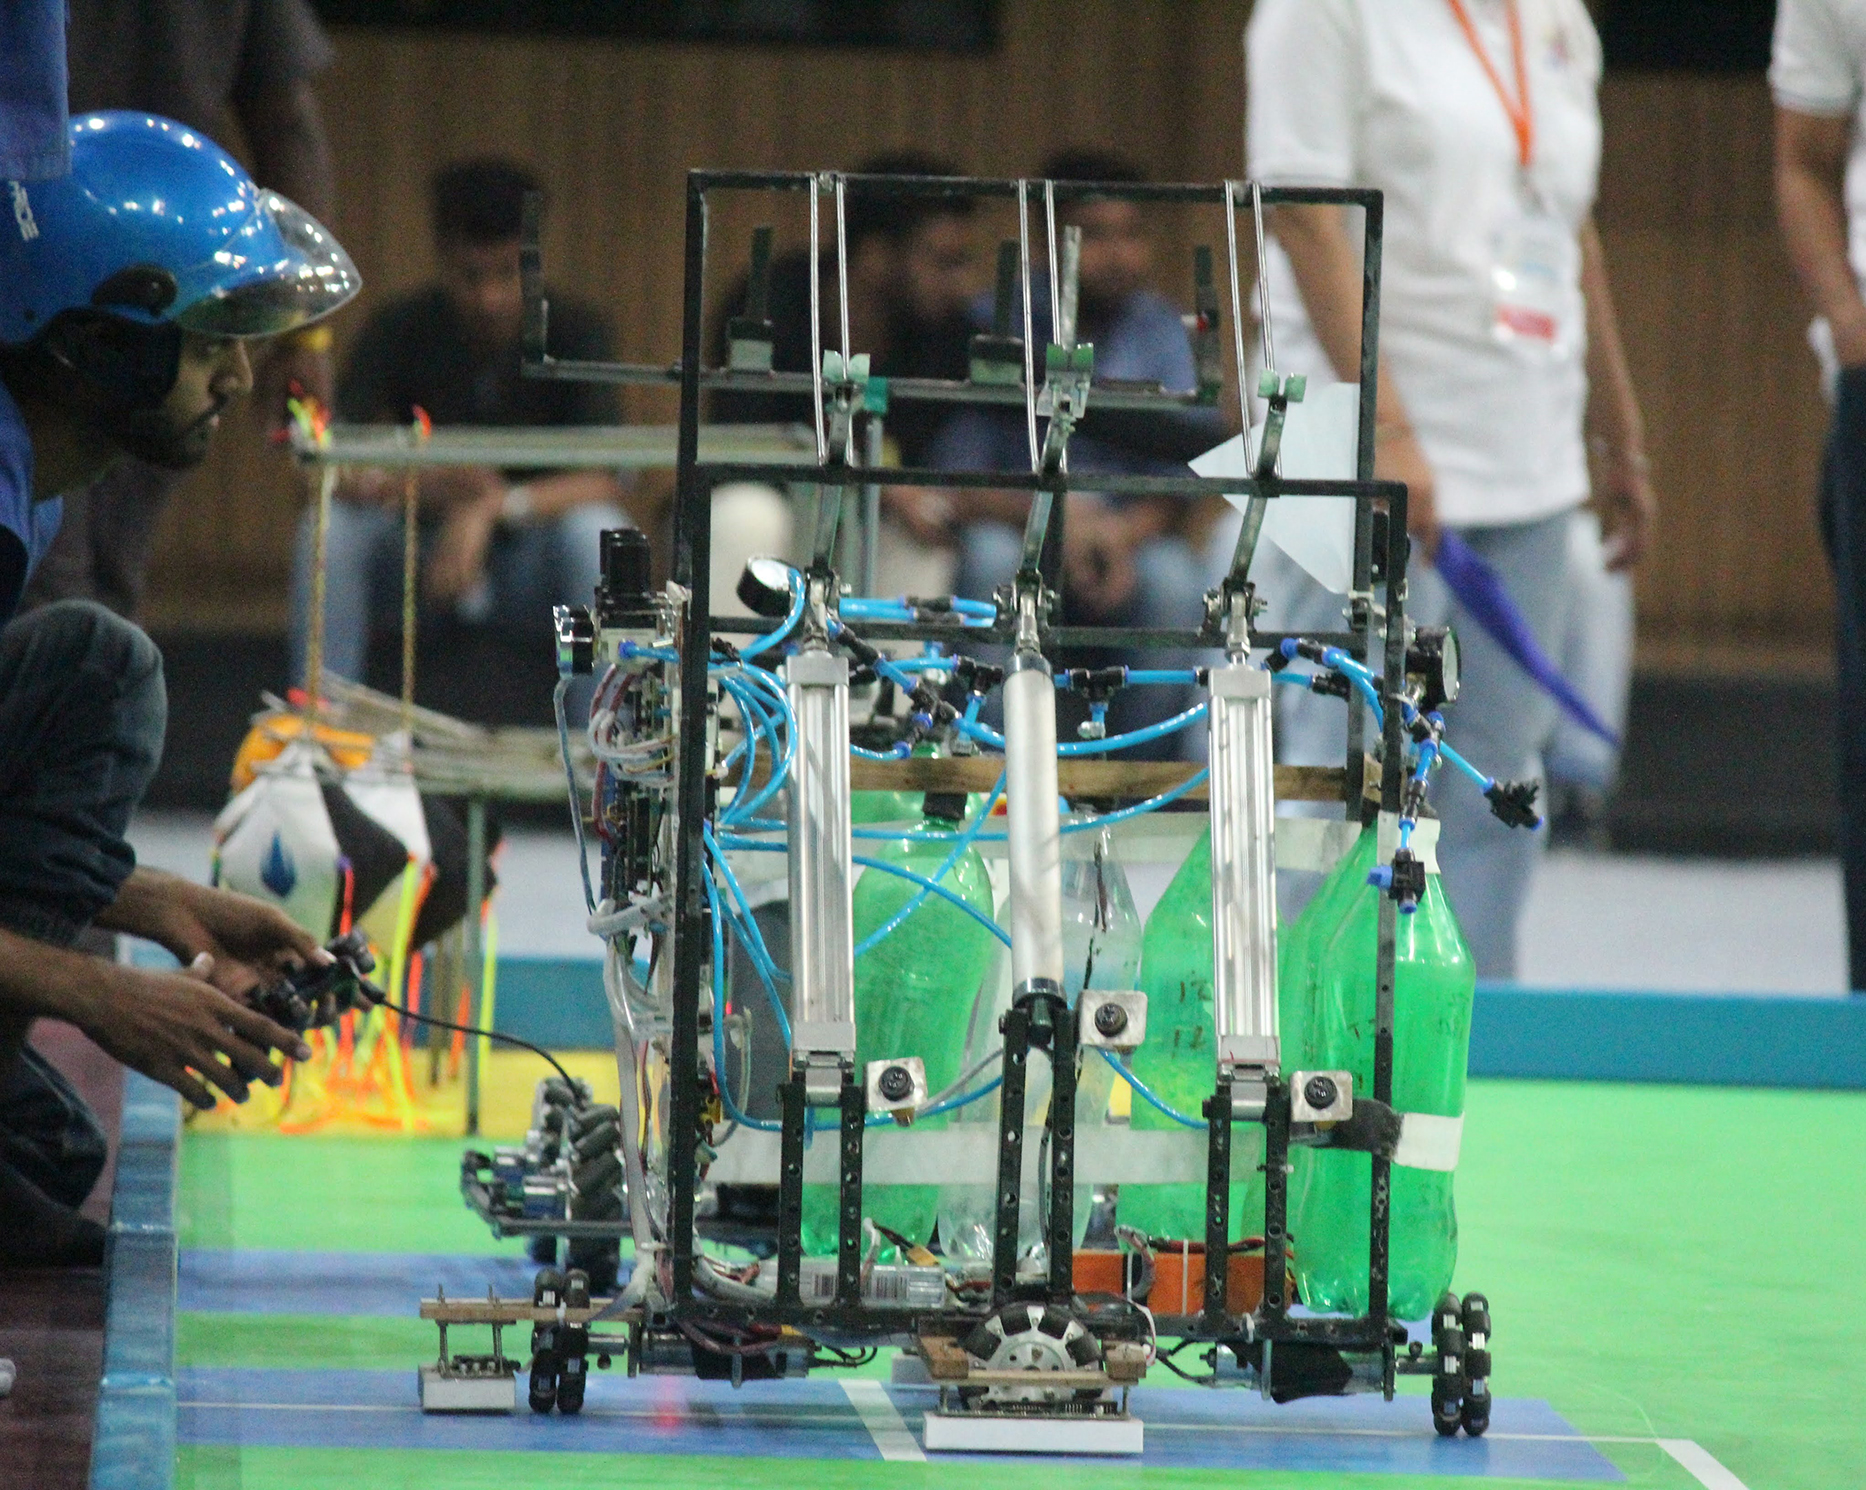
Image 1: Autonomous Shuttle Launching Robot
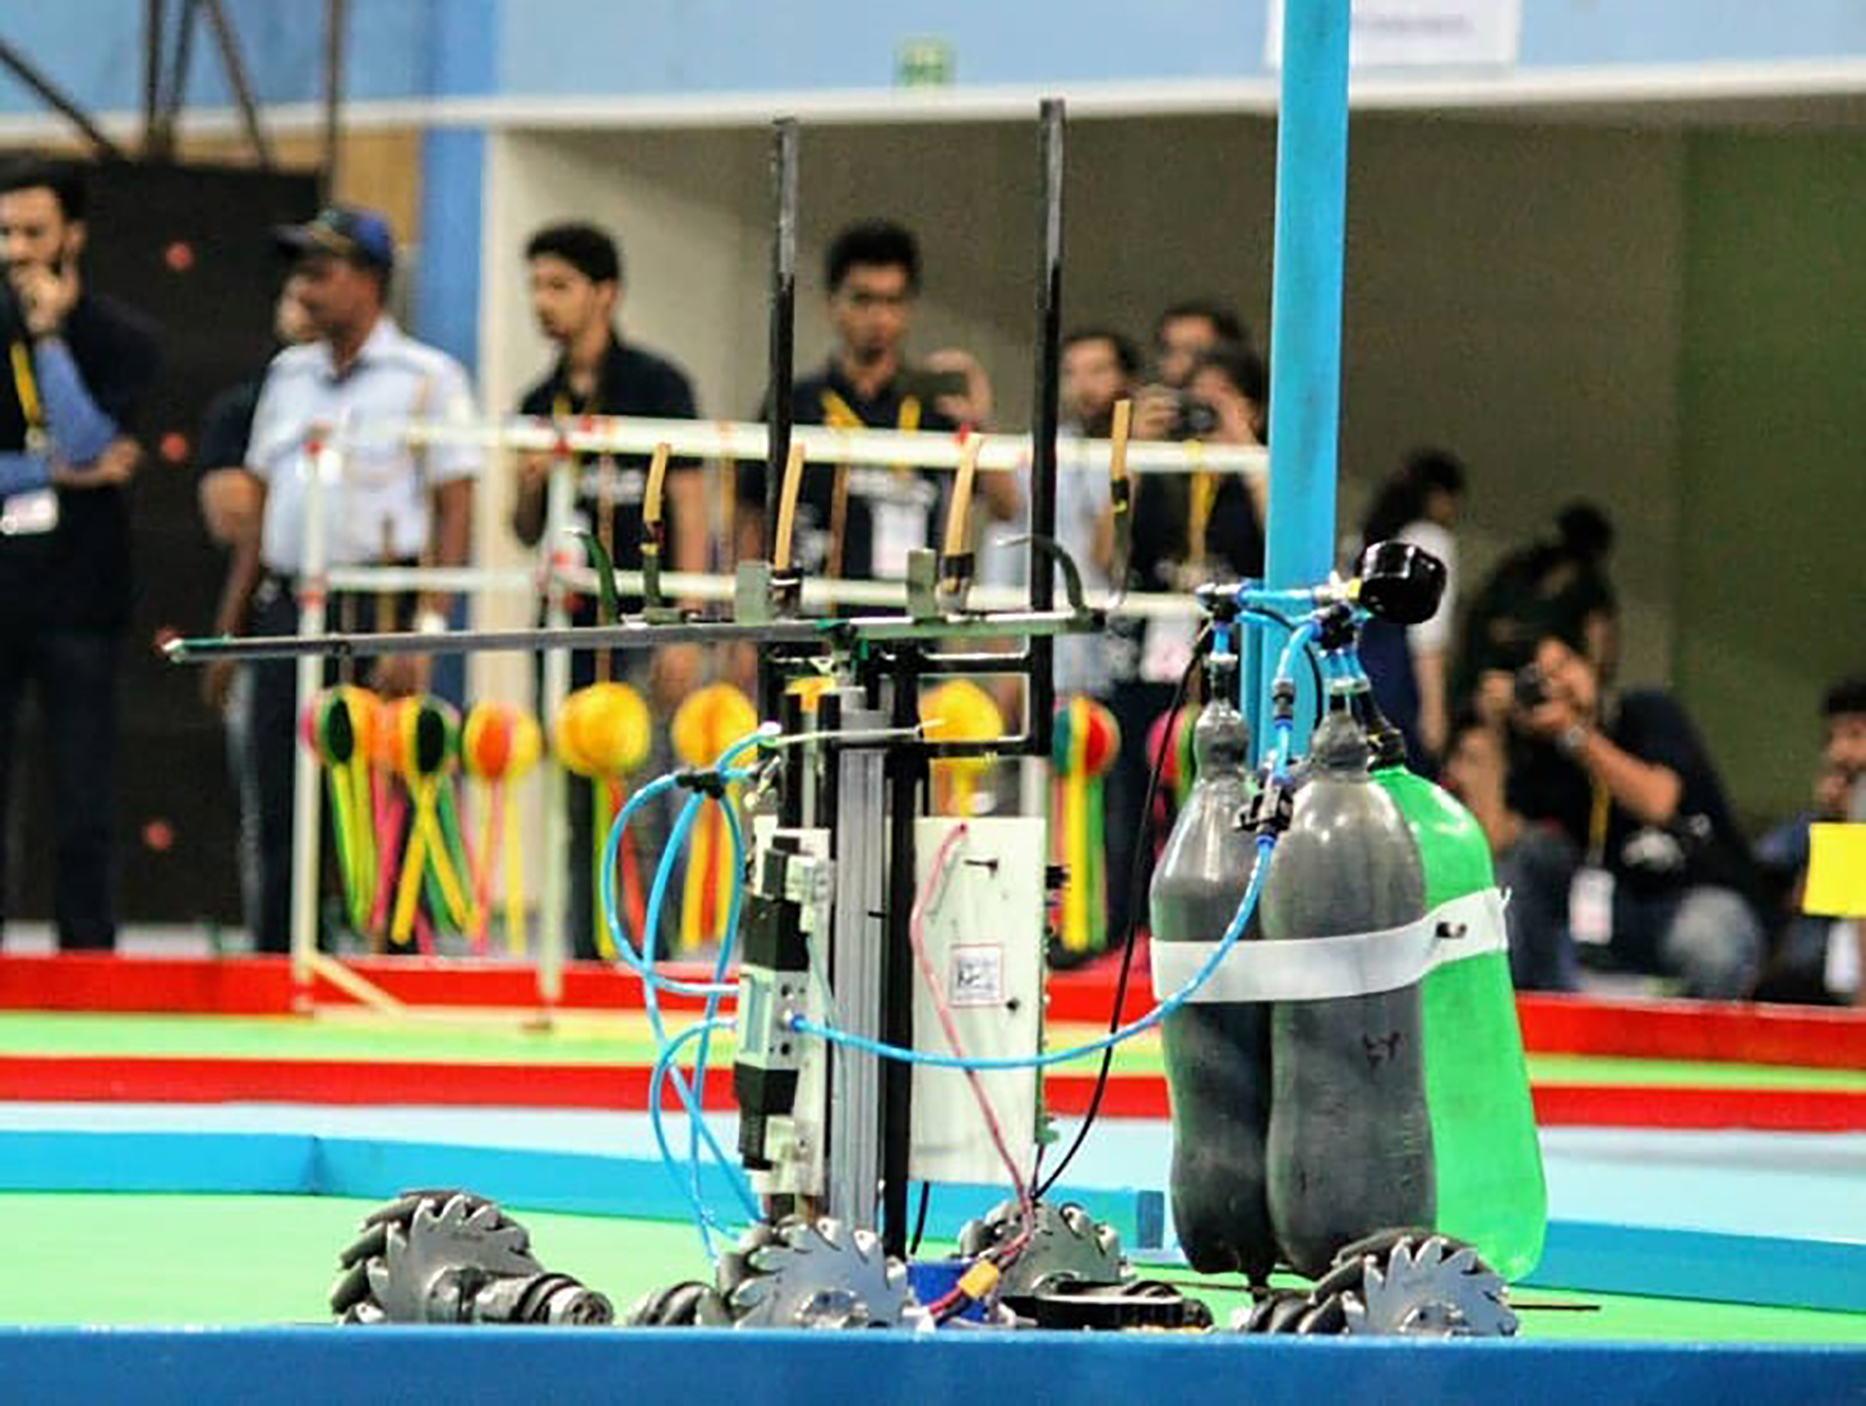
Image 2: Manual Robot - responsible for shuttlecock transfer to the Autonomous Robot.
As a core team member, I worked with a 40-member robotics team at ABU Robocon India, contributing to the design, manufacturing, testing, and integration of power and logic interfaces for both manual and autonomous robots.
Shuttle Launching Autonomous Robot and Manual Robot (ABU Robocon 2018): The team designed and developed two robots, a manually operated robot and a fully autonomous robot. The manual robot was responsible for transferring shuttlecocks to the autonomous robot, while the autonomous robot used a differential-drive system and a pneumatically actuated catapult mechanism to launch shuttlecocks through circular hoops. My contributions focused on the electrical and control systems, including custom hardware design, sensor testing, motor control, pneumatic actuator optimization, and the creation of schematic symbols and PCB footprints for new components.
Autonomous Quadruped Robot and Manual Robot (ABU Robocon 2019): The team developed a holonomic-drive manual robot with force-vector analysis, an optical ray encoder for feedback, and a servo-based gripper for locking and releasing mechanisms. We also developed a pneumatic loading and throwing mechanism and a fully autonomous quadruped robot using Trot Gait analysis for locomotion. As part of the electrical team, I designed the PCBs that formed the main electrical interfaces for both robots, including the PCB for Manual and Autonomous Robots, Battery Fuel Gauge, and LCD & Relay Breakout Board. I was also involved in their testing, integration, and bring-up.