PCB for Manual and Autonomous Robots
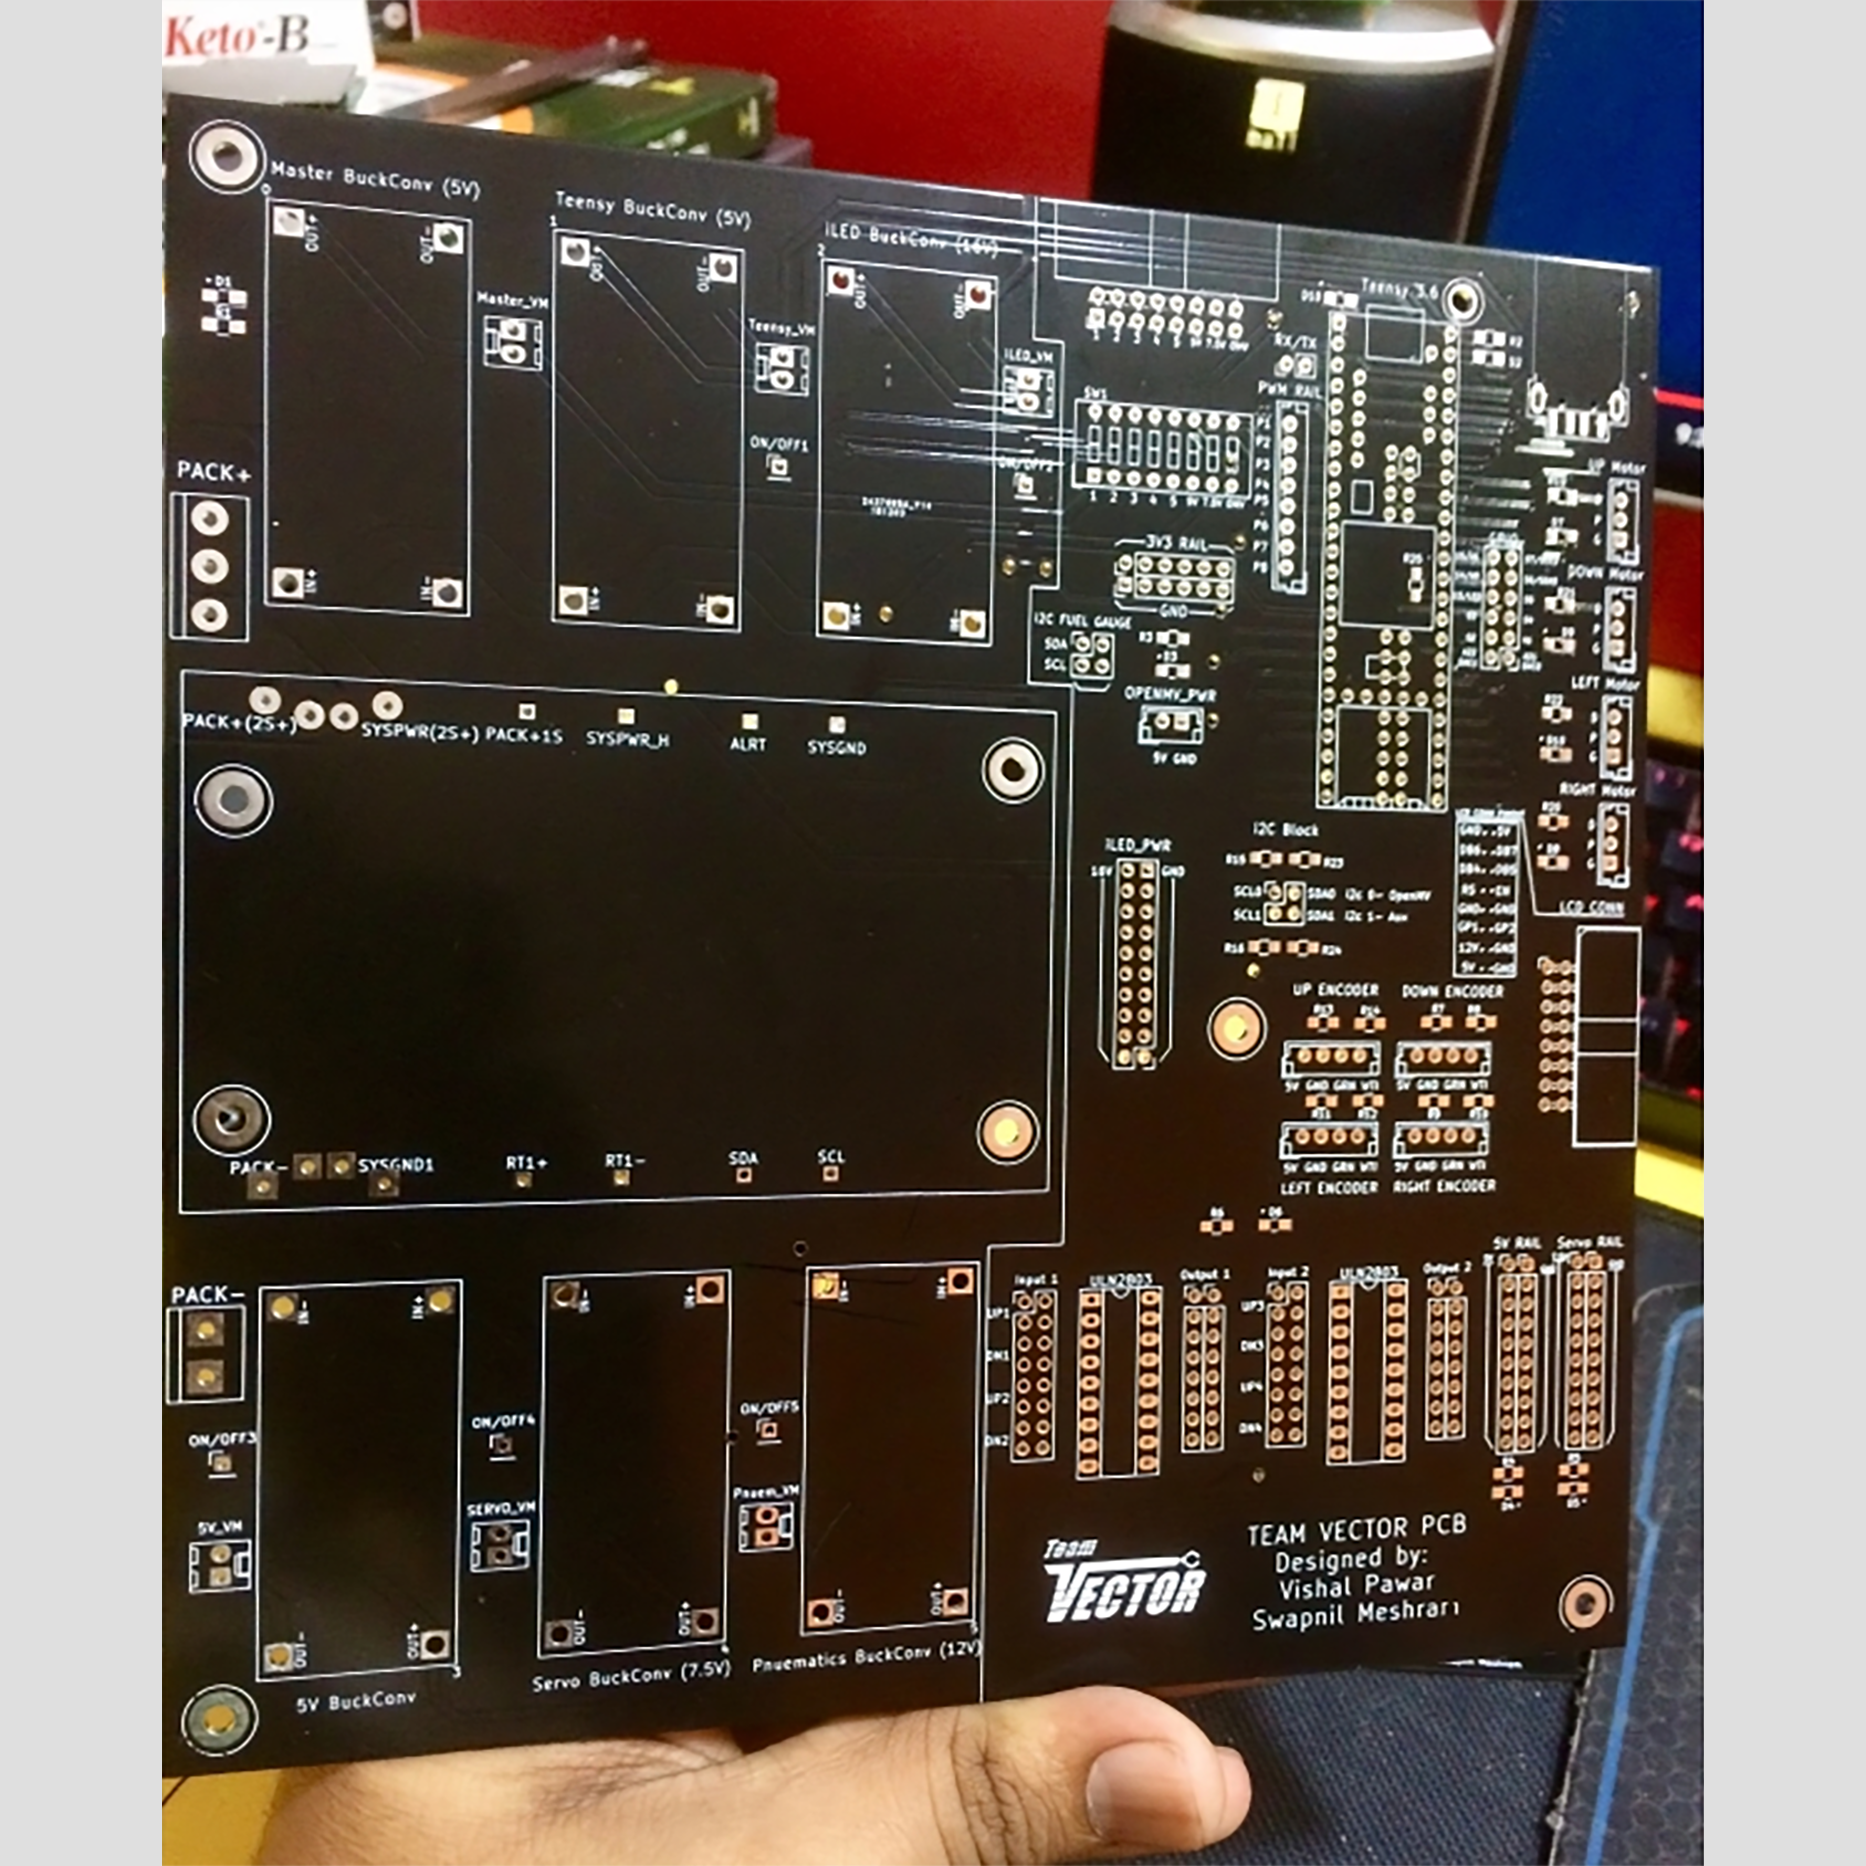
Image 1: PCB for Manual and Autonomous Robots (Top Side)
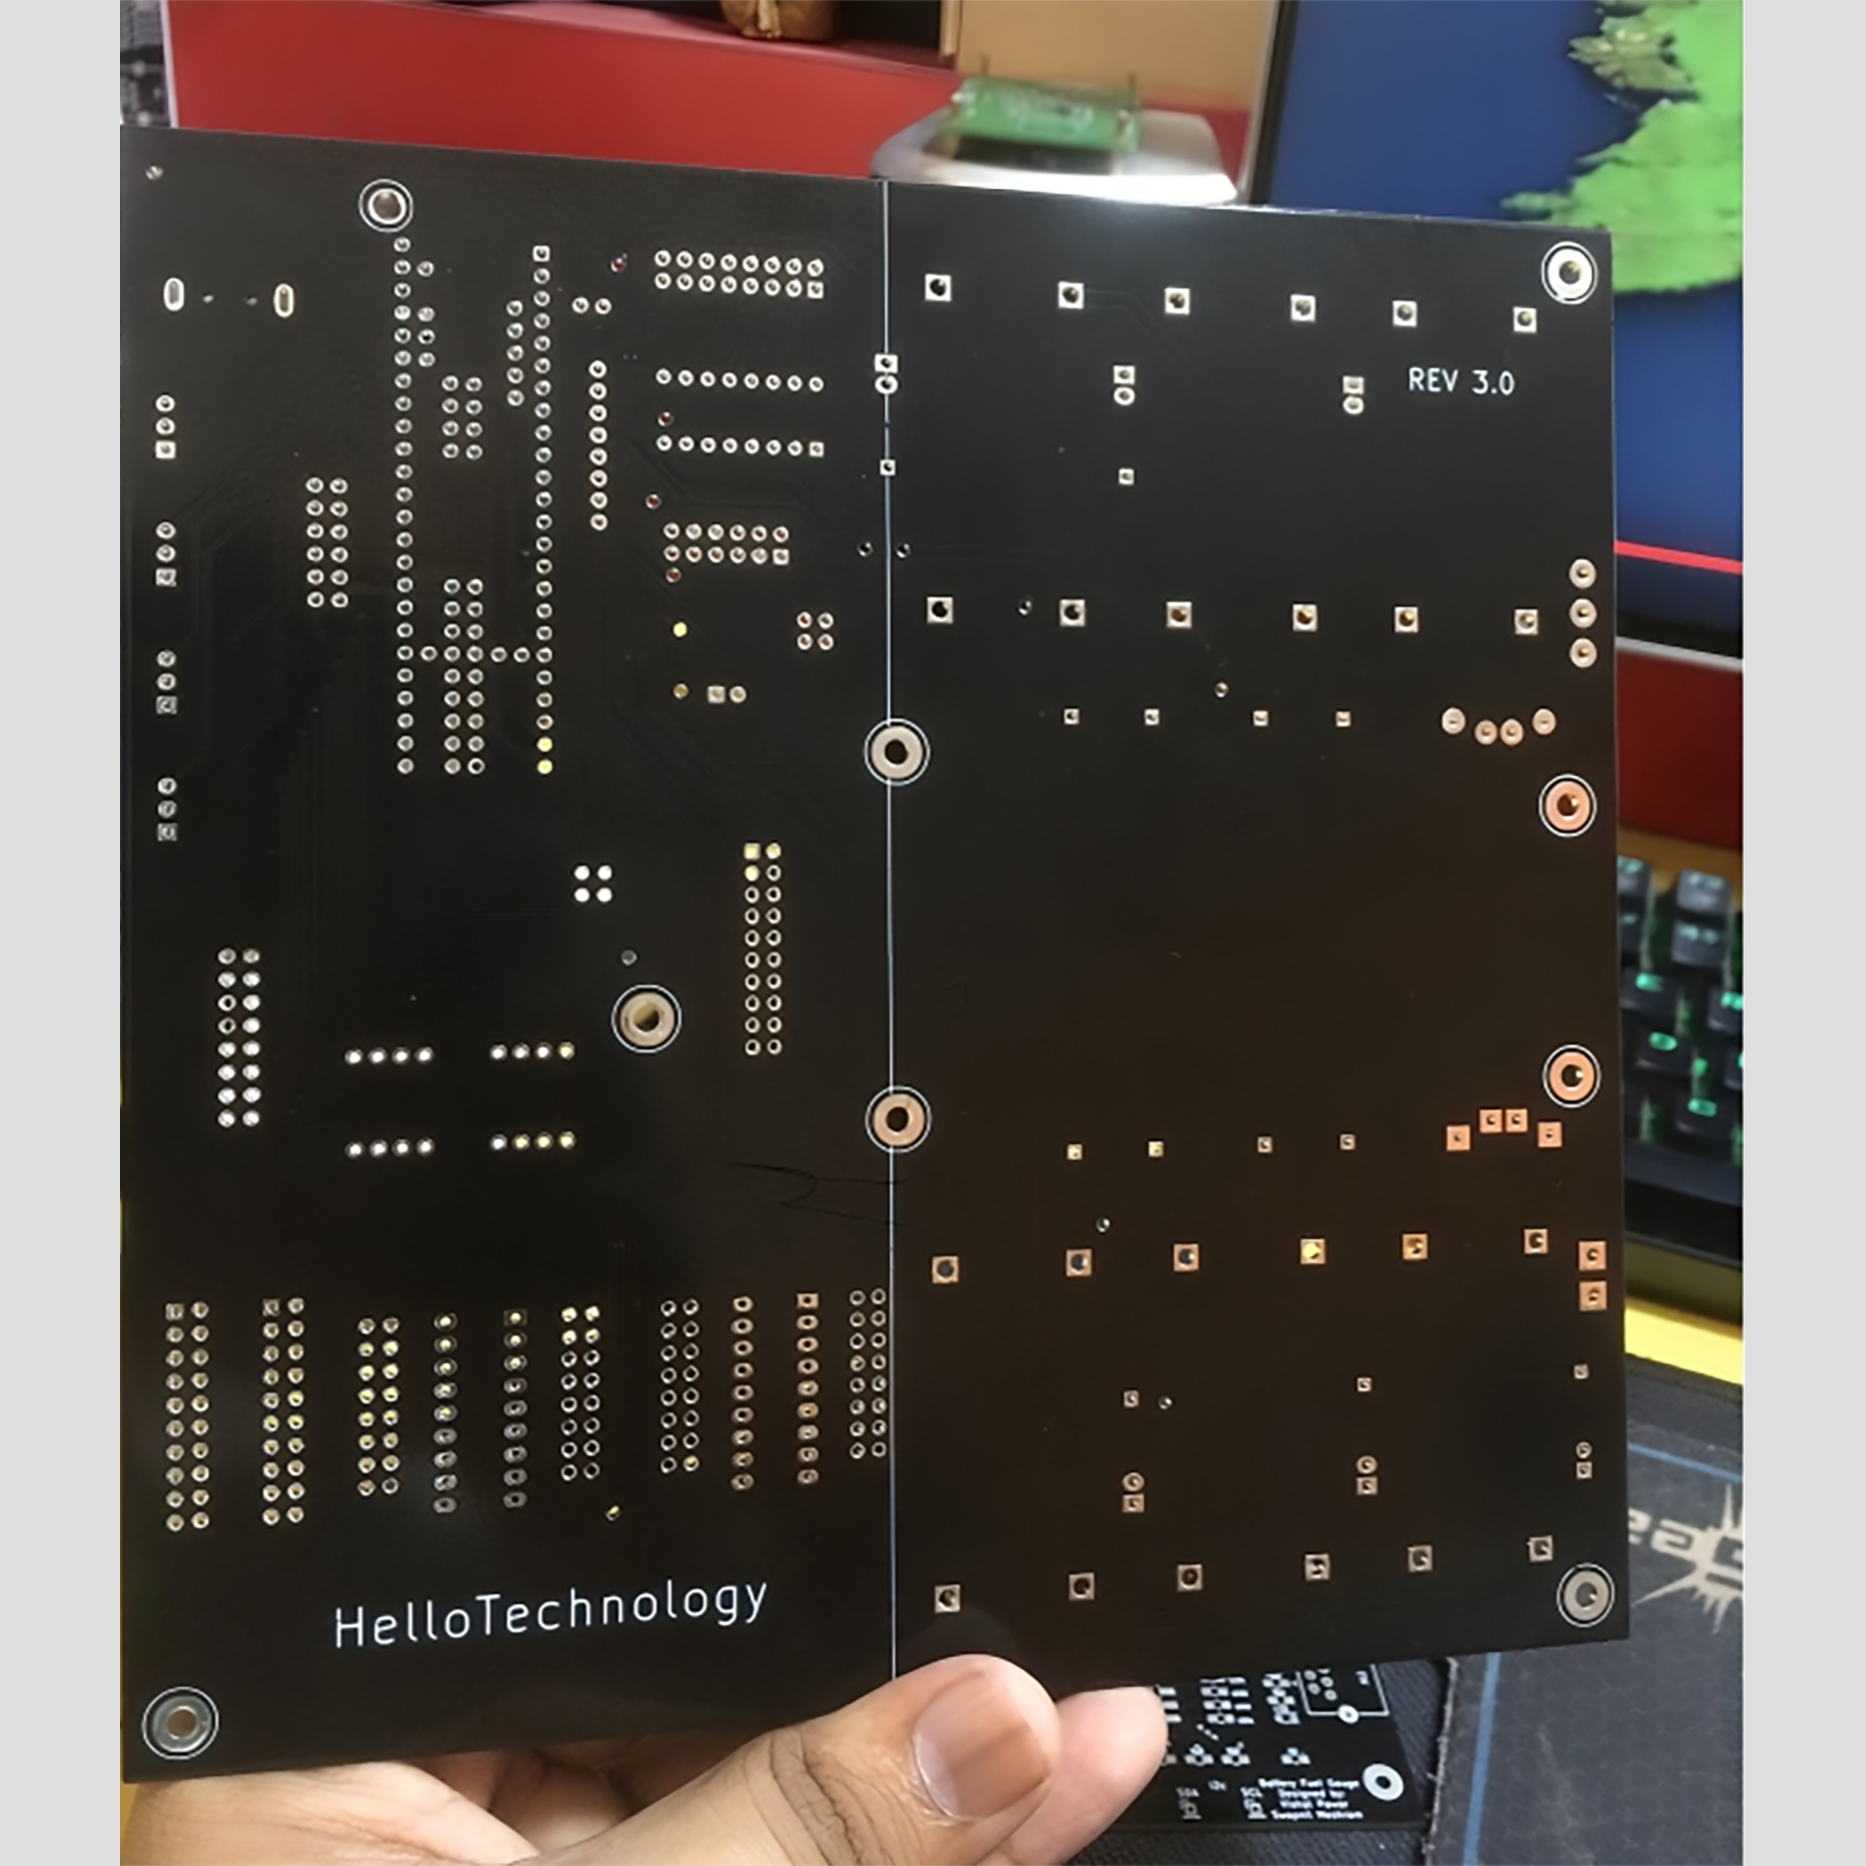
Image 2: PCB for Manual and Autonomous Robots (Bottom Side)
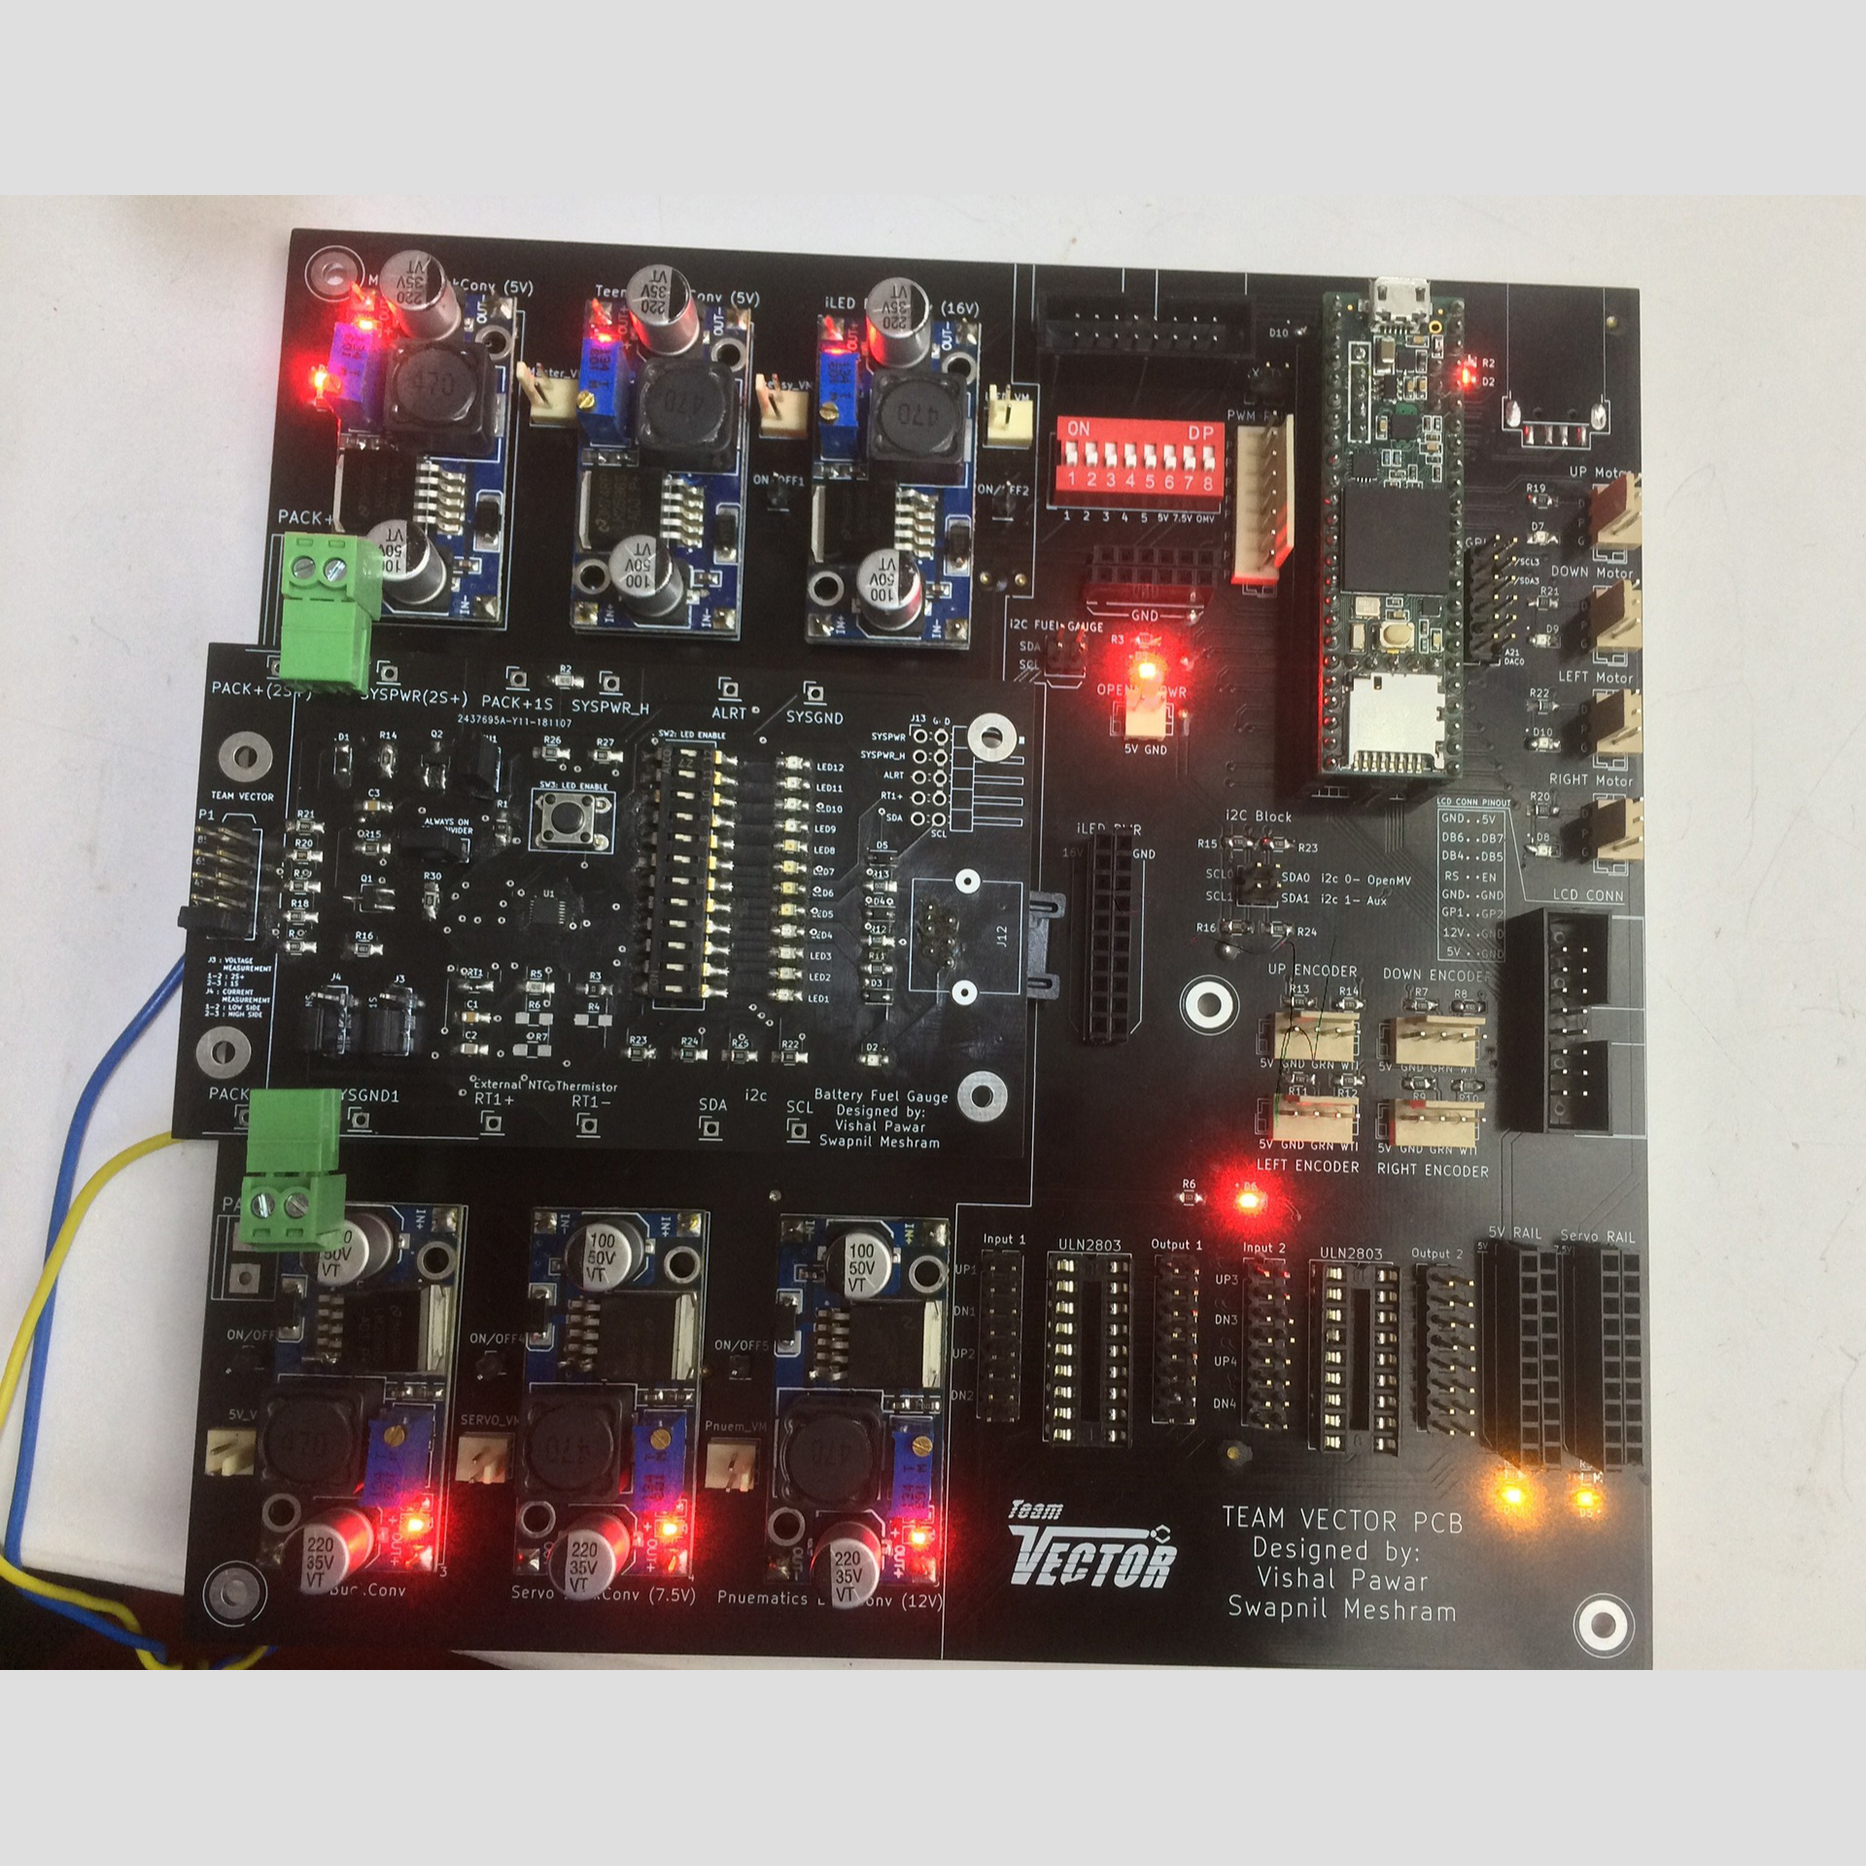
Image 3: PCB for Manual and Autonomous Robots (Assembled & Tested)
This project involved the design and development of a double-layer PCB for both manual and autonomous robots. The board was designed as a centralized platform for power management, sensor and actuator interfacing, and battery monitoring.
A key feature of the design was the primary/secondary configuration of the buck converters, which allowed the primary converter to control the activation and deactivation of the secondary converters as required. This provided more flexible power distribution across the robot's subsystems.
The PCB supported multiple voltage levels through integrated buck and boost converter modules and included interfaces for a range of sensors and actuators. These included Serial, USB, PWM, I2C, 12-pin GPIO with ADC and DAC, LCD, pneumatic control, and rotary optical encoder interfaces.
The board also incorporated a customized Battery Fuel Gauge system for monitoring both single-cell and multi-cell lithium battery packs, providing an integrated solution for battery-status monitoring alongside the robot's other electrical and control functions.