Autonomous & Undersea Systems Division
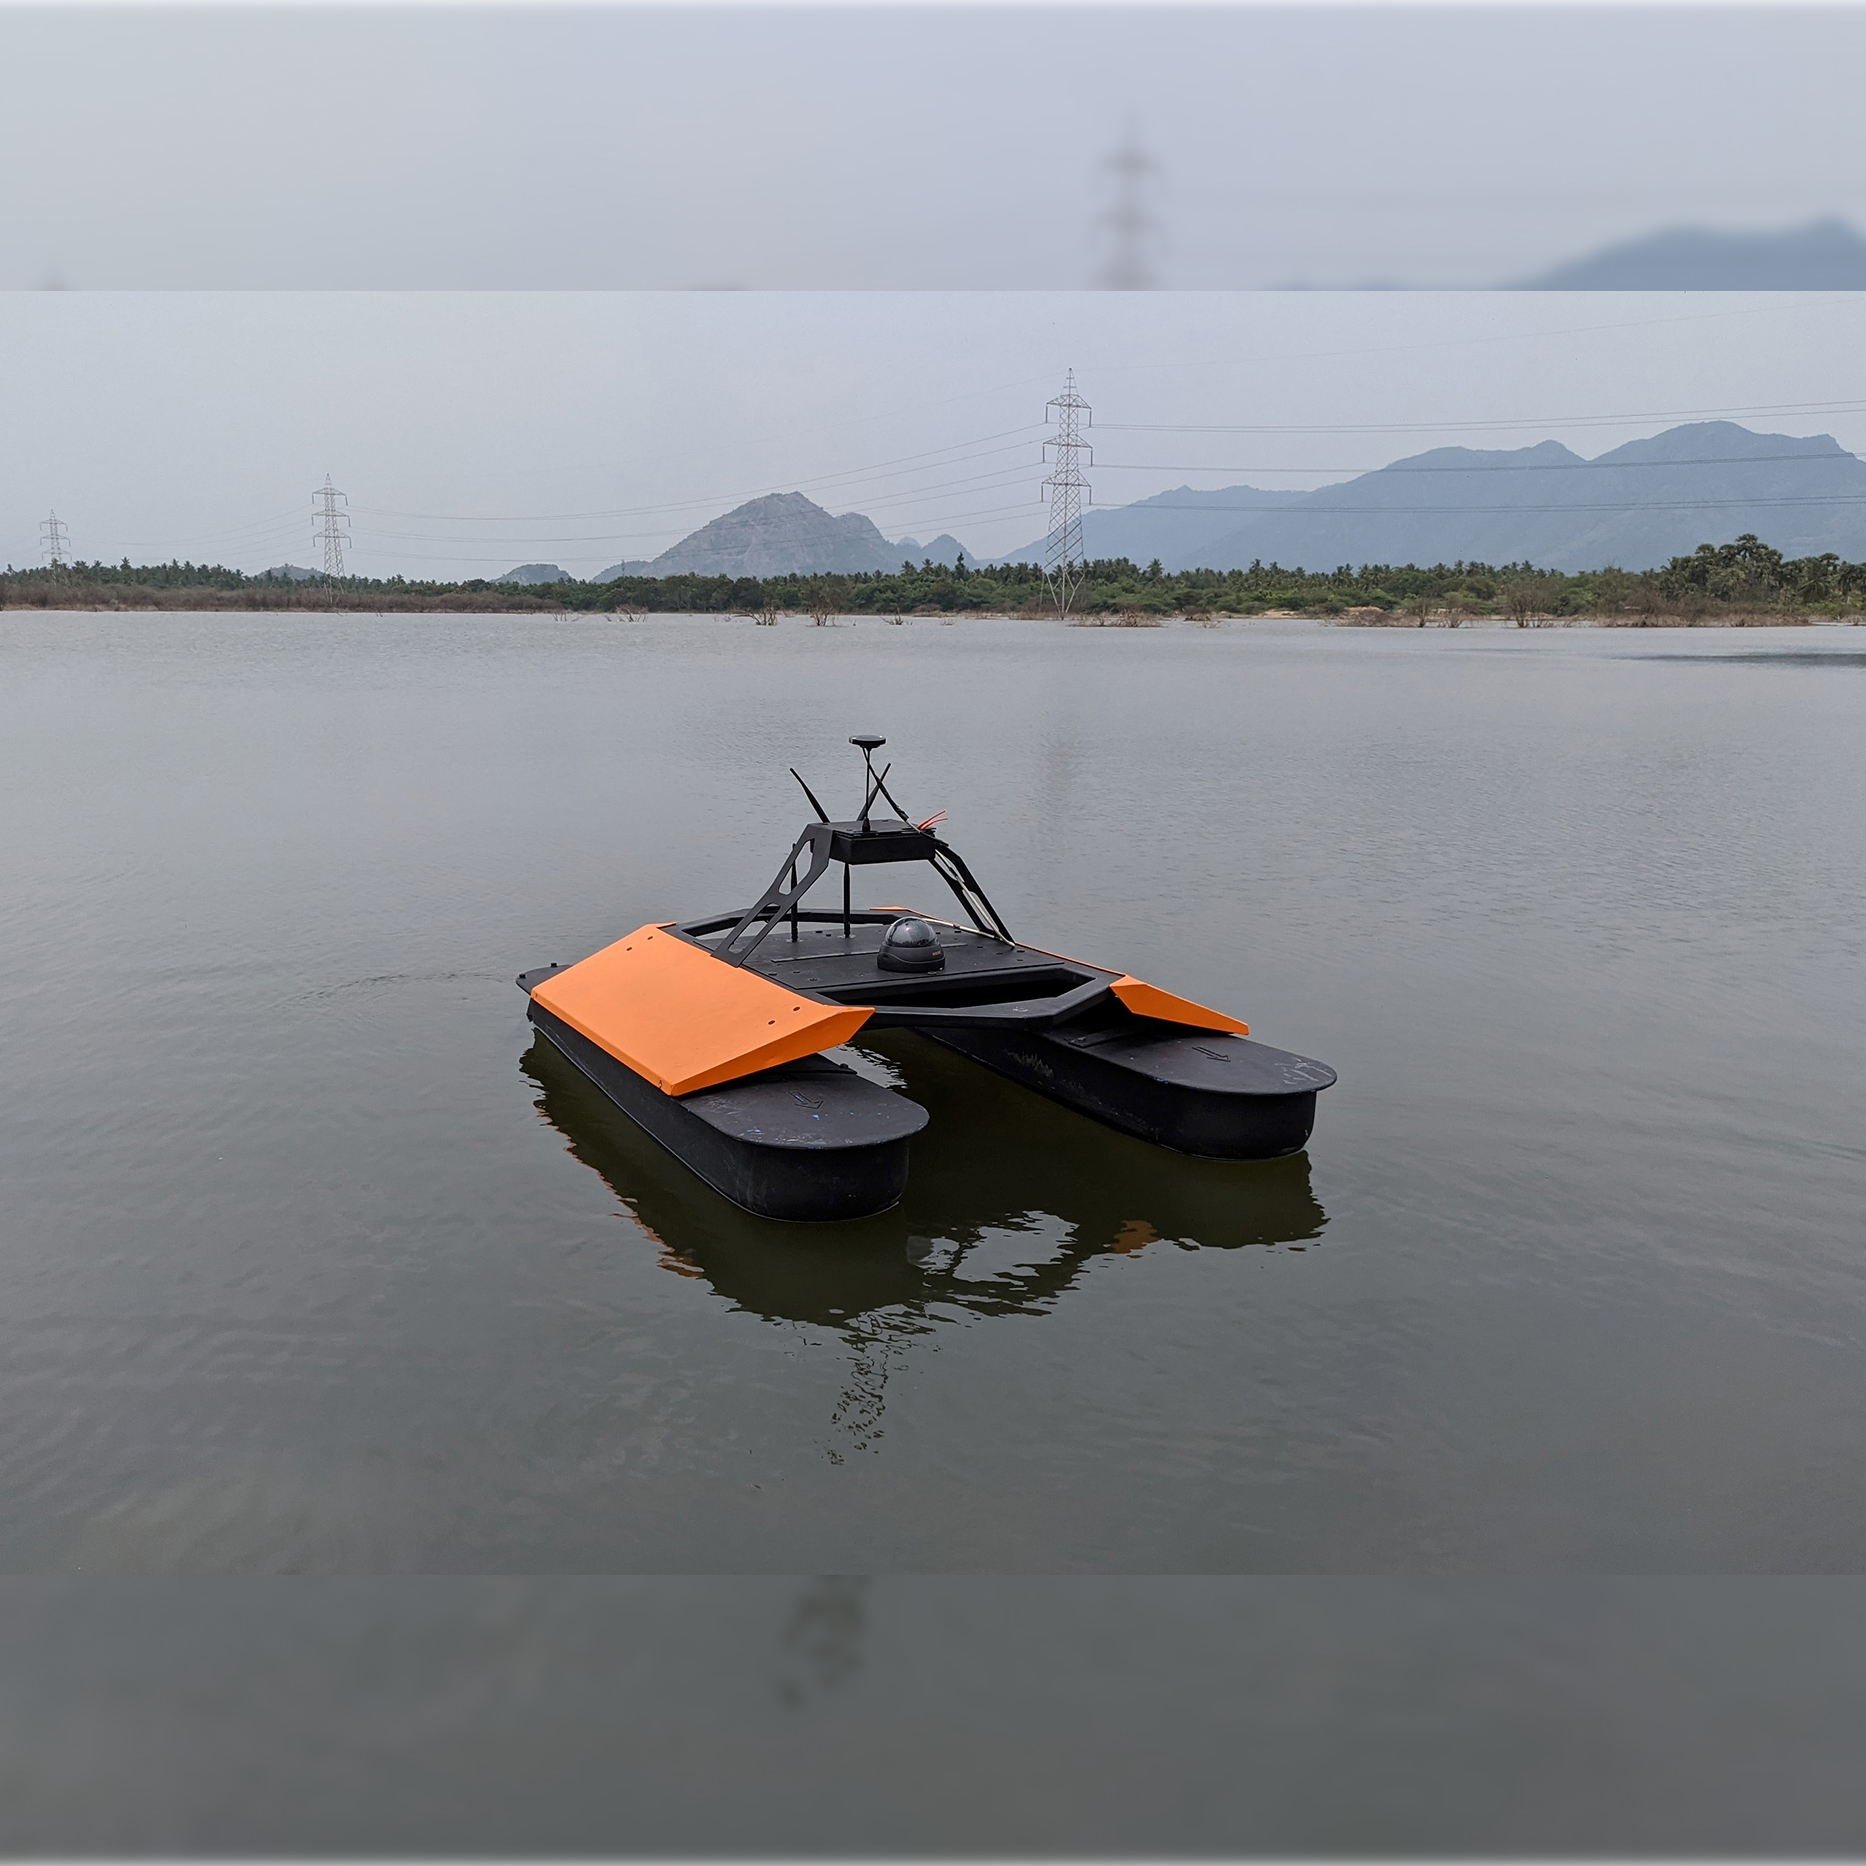
Image 1: Autonomous Surface Vessel
Image source: Aerospace Engineers Private Limited, 2022
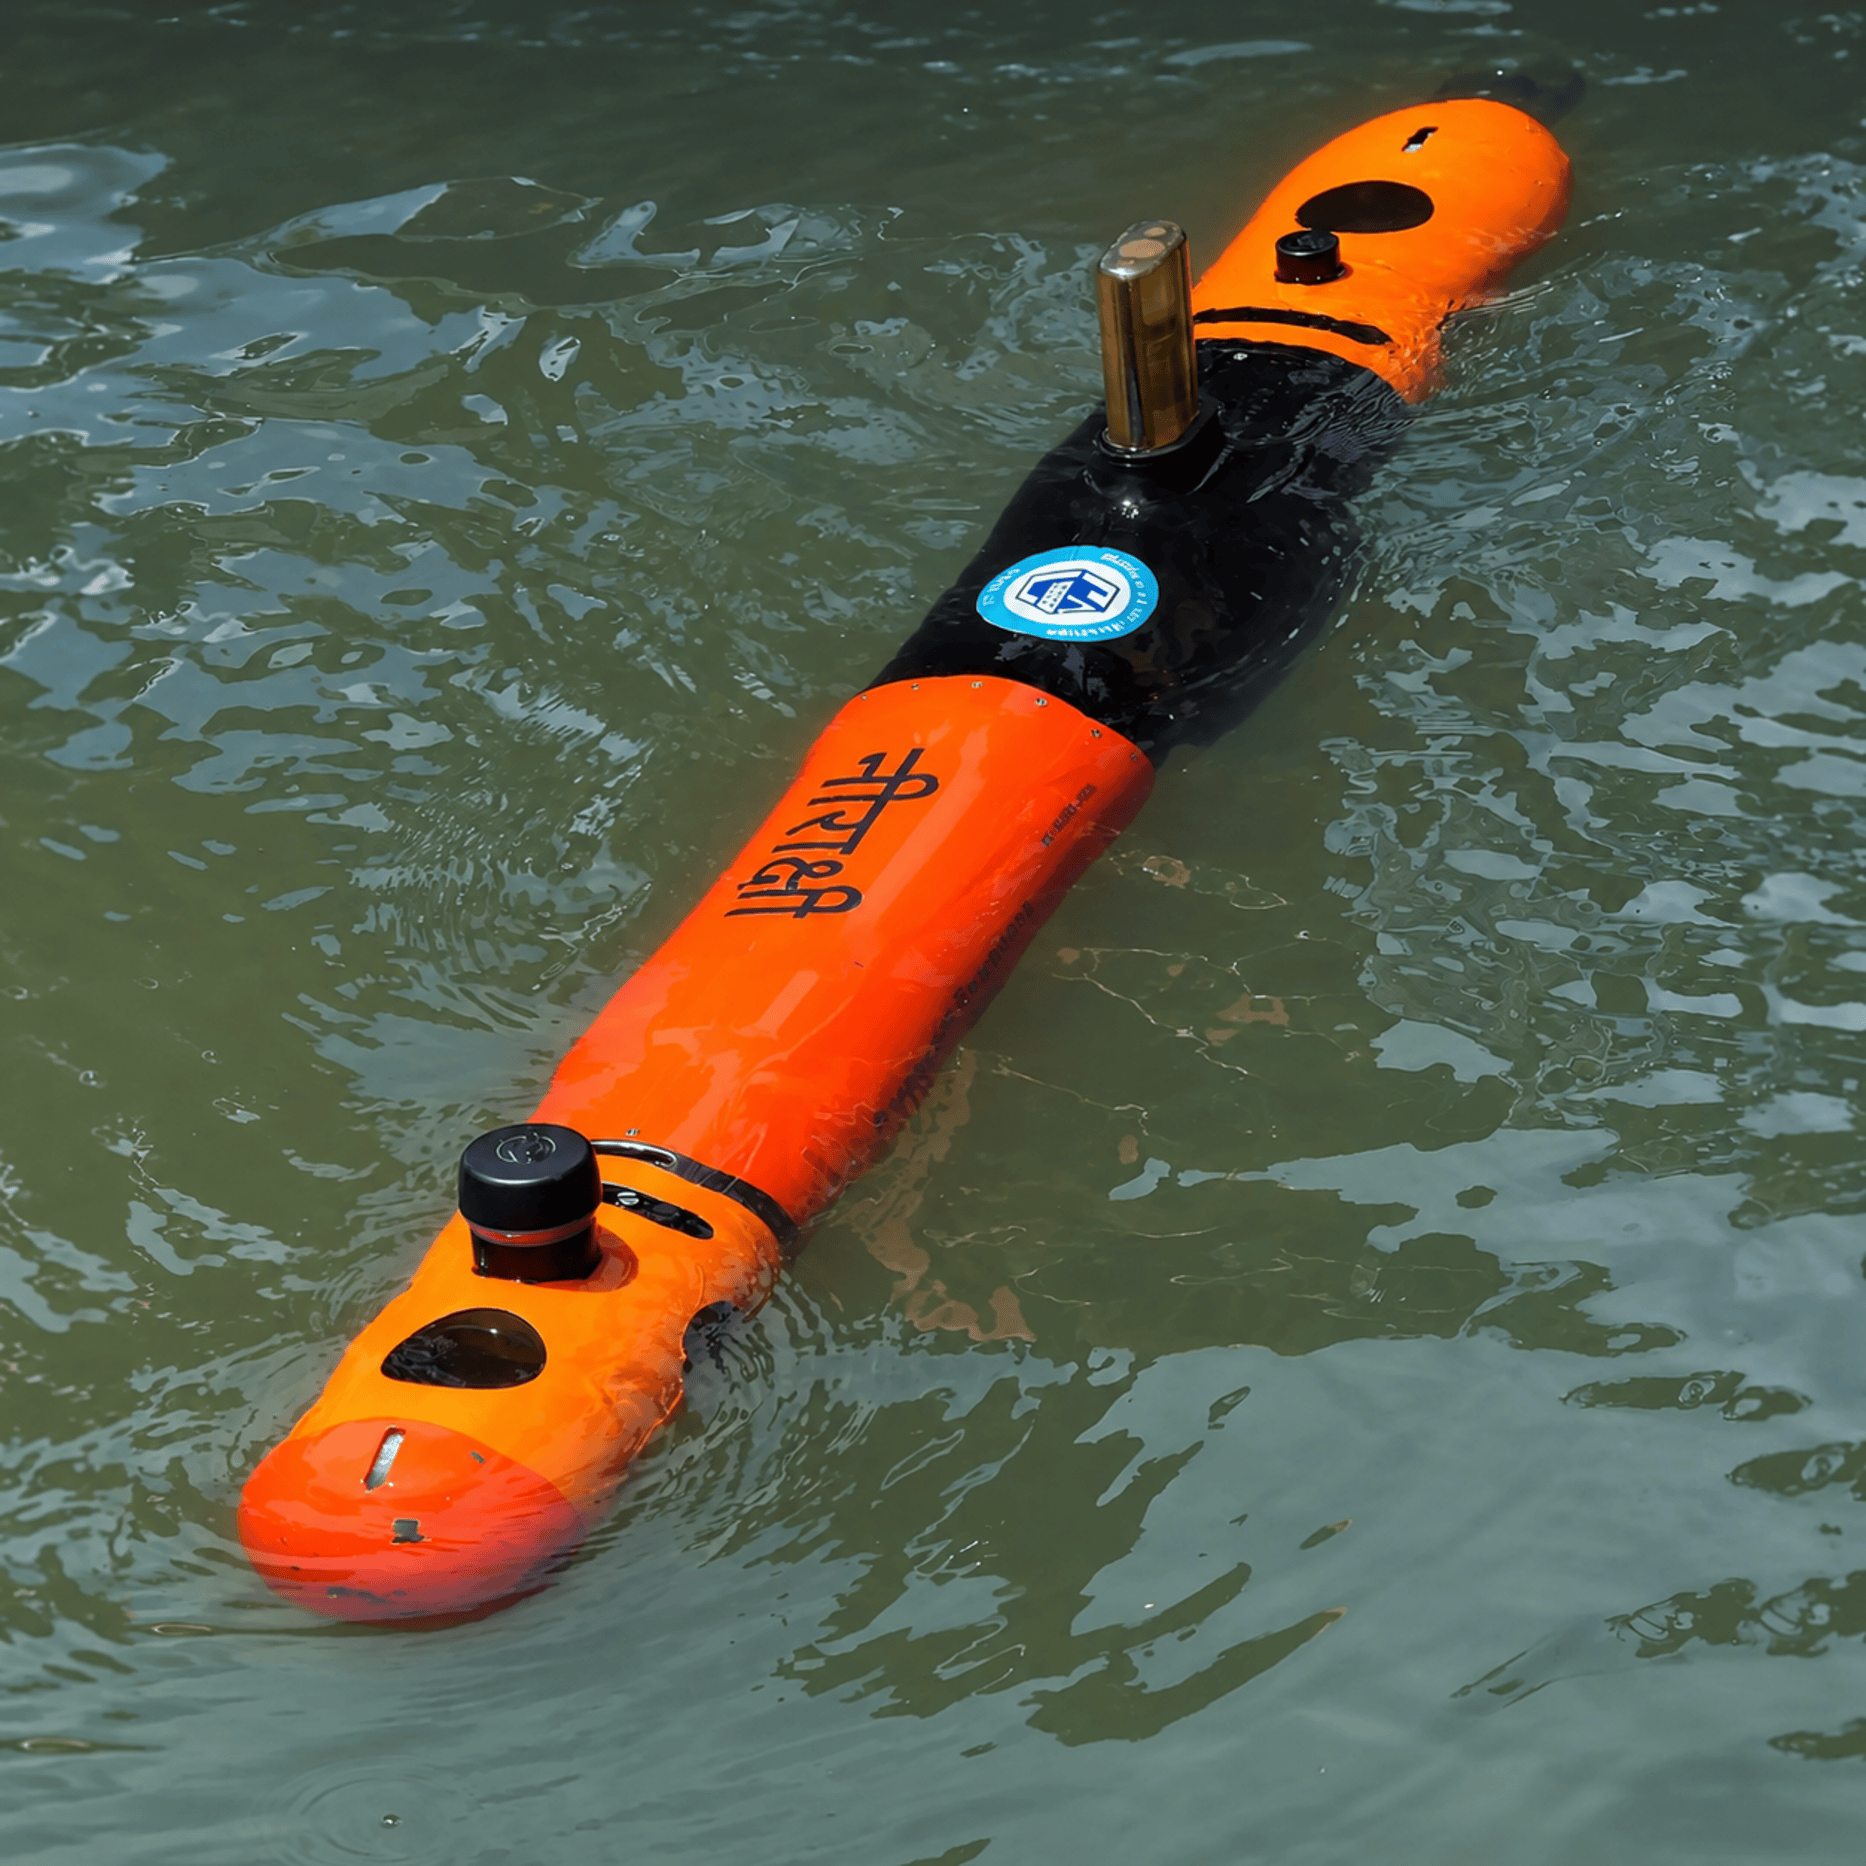
Image 2: Autonomous Underwater Vehicle (named Neerakshi AUV)
Image source: Vajiram & Ravi (IAS Study Center), 2023, https://vajiramias.com/
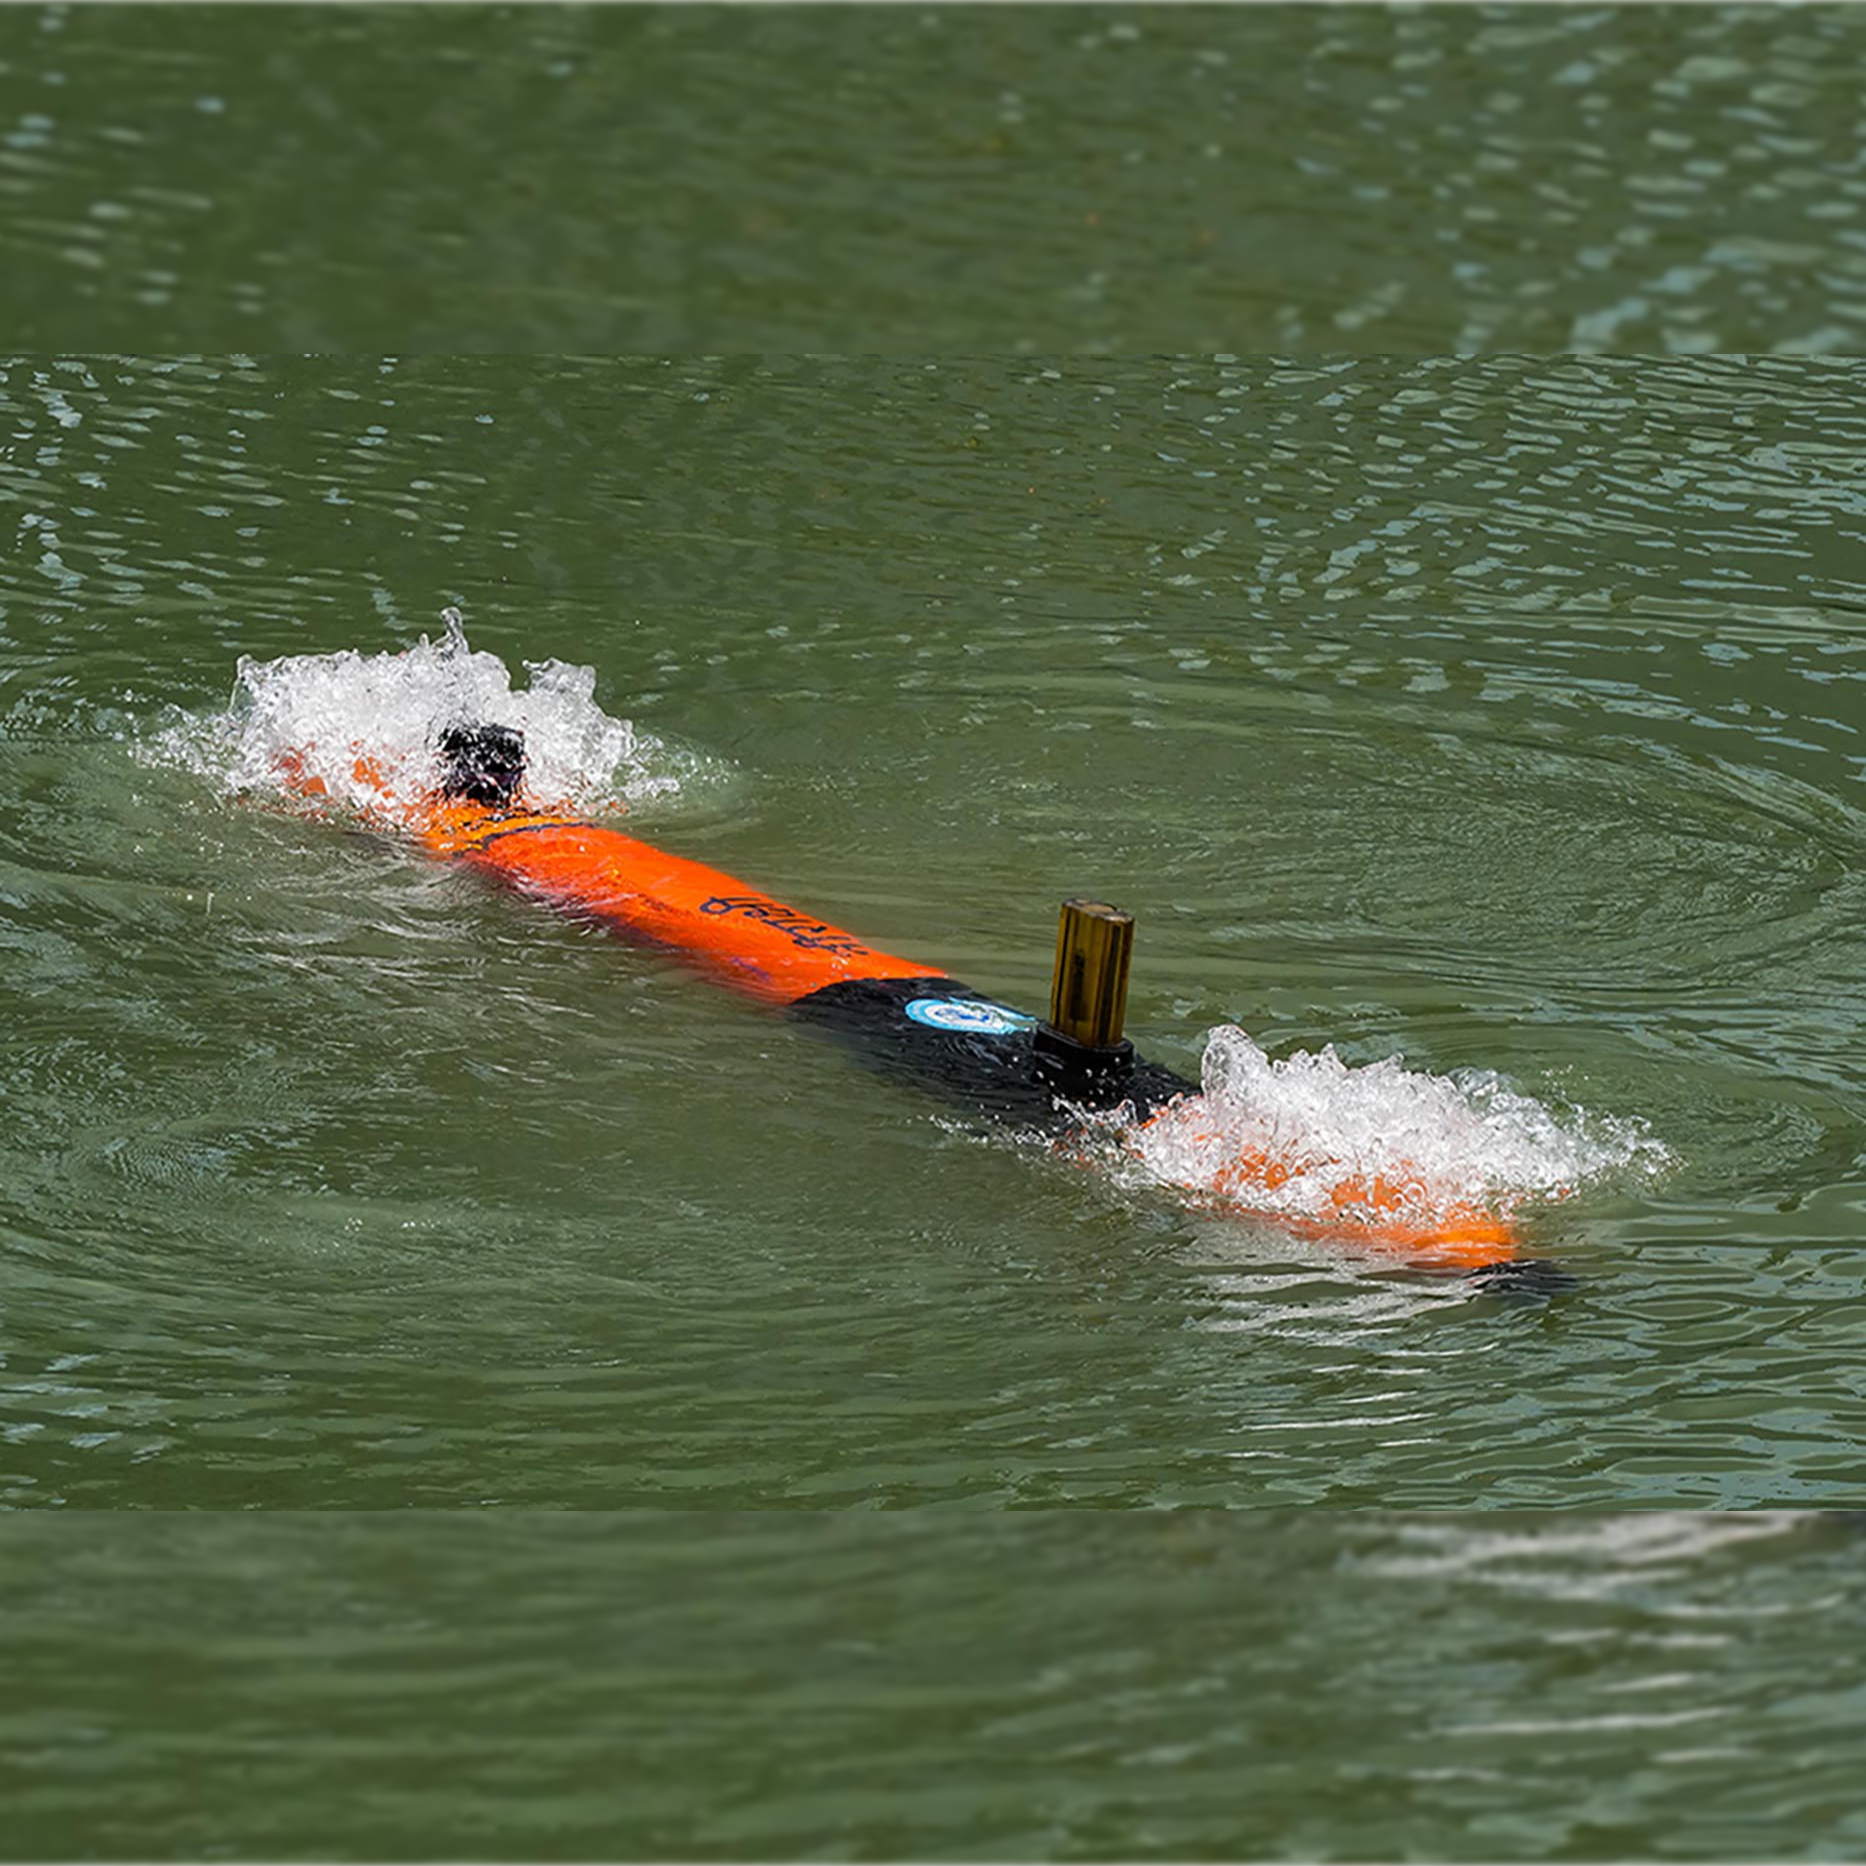
Image 3: Neerakshi AUV maneuvering through water with surface current
Image source: The Indian Express, 2023, https://indianexpress.com/
At the Autonomous & Undersea Systems Division of Aerospace Engineers Private Limited (AEPL), I led the research and development of electrical and embedded systems for unmanned marine vehicles, contributing to the design and development of autonomous platforms for underwater and surface operations.
A key highlight was the development of the Neerakshi Autonomous Underwater Vehicle (AUV), a 2.15-meter-long cylindrical vehicle weighing approximately 45 kg, with nearly 4 hours of endurance and an operating depth of up to 300 meters. The vehicle was designed for applications including underwater surveys, mine detection, and mine disposal. I also contributed extensively to other marine platforms, including Remotely Operated Vehicles (ROVs) and Autonomous Surface Vessels (ASVs).
My role covered the full product development lifecycle, from initial hardware concepts to fully integrated prototypes. This included component selection, schematic design, multilayer PCB design, board bring-up, and system-level integration. I also worked closely with cross-functional engineering teams to integrate custom-designed electronics, underwater sensors, mission payloads, and communication systems.
A significant part of my work involved improving the AUV's electrical architecture and addressing practical challenges in power distribution, thermal management, and propulsion. I redesigned the core power distribution system to simplify internal wiring and improve system modularity. I also worked on the propulsion drive by improving thermal management and optimizing Electronic Speed Controller (ESC) tuning to improve overall endurance.
Throughout the development process, I maintained documentation across design, testing, and debugging to support troubleshooting, knowledge transfer, and continued development across projects.